RP Store Tìm linh kiện theo mã, gửi BOM nhận báo giá Gửi BOM

Bộ điều khiển fuzzy

Collapse
This is a sticky topic.
X
X
 
  • Giờ
  • Show
Clear All
new posts
  • falleaf
    PIC Bang chủ
    • May 2005
    • 2627

    #1

    Bộ điều khiển fuzzy

    Các bạn có thể download chương trình fuzzytech phiên bản 5.52f tại đây và bản crack đi kèm.

    Chúc vui.
    Công ty TNHH Thương mại và Giao nhận R&P
    store.hn@rpc.vn - store.hcm@rpc.vn

    Học PIC như thế nào?
  • tinhthanthep
    Đệ tử 6 túi
    • May 2005
    • 141

    #2
    Không có password thì làm sao cài được chương trình này hả Admin?

    Comment

    • falleaf
      PIC Bang chủ
      • May 2005
      • 2627

      #3
      Đó là ý tôi muốn các bạn ít ra cũng phải lên tham quan thử cái trang FuzzyTech xem nó ra làm sao, chứ tôi không muốn các bạn cứ thế là down về xài mà không quan tâm gì đến nó cả.

      Trong FuzzyTech nó có hướng dẫn chi tiết làm sao để cài đặt.

      pw: purple

      Sau đó các bạn dùng một trong 2 pw này cho phần tiếp theo.
      pw: 00000
      pw: 123456

      Chúc vui.
      Last edited by falleaf; 16-11-2005, 08:08 PM.
      Công ty TNHH Thương mại và Giao nhận R&P
      store.hn@rpc.vn - store.hcm@rpc.vn

      Học PIC như thế nào?

      Comment

      • forgetmenot
        Nhập môn đệ tử
        • Nov 2005
        • 6

        #4
        Đây là các bước cài đặt phần mềm fuzzyTech 5.52 từ nguồn của anh admin.Tôi đã cài đặt thành công. Các bạn cứ làm y như thế này là dùng được.
        http://picvietnam.com/download/Fuzzy...YEN.201105.pdf
        Người vá trời lấp bể
        Kẻ đắp lũy xây thành
        Ta chỉ là chiếc lá
        Phận của mình là xanh

        Comment

        • forgetmenot
          Nhập môn đệ tử
          • Nov 2005
          • 6

          #5
          Fuzzy Logic Controller in Matlab7.0

          Bài viết sau mô tả quá trình thiết kế và mô phỏng một bộ điều khiển mờ trên Matlab.
          Bộ điều khiển mờ ở đây gồm 2 input và 1 output với 3 hàm thuộc cho mỗi input và 5 hàm thuộc cho output.
          Bộ luật gồm có 5 luật.
          http://picvietnam.com/download/Fuzzy...YEN.201105.pdf
          Người vá trời lấp bể
          Kẻ đắp lũy xây thành
          Ta chỉ là chiếc lá
          Phận của mình là xanh

          Comment

          • ncngon
            Nhập môn đệ tử
            • May 2006
            • 1

            #6
            Em dang quan tam den viec dua Fuzzy controller len Vi dieu khien ho PIC chang han. Bac nao, co phan mem hay co tai lieu noi ve van de nay, xin vui long post len nhe.

            Cam on rat nhieu
            ncngon

            Comment

            • falleaf
              PIC Bang chủ
              • May 2005
              • 2627

              #7
              Bạn xem bài toán mẫu viết bằng matlab, từ matlab chuyển sang C hoàn toàn không khác gì nhau. Và chuyển qua vi điều khiển thực chất chỉ là thêm việc xuất các tín hiệu ra port, hoặc đọc các giá trị input từ các port vào thôi.

              Chính vì vậy, vấn đề chính là bạn cần tìm hiểu bộ điều khiển fuzzy thật rõ ràng, phần lập trình dùng PIC hoàn toàn không phải vấn đề.

              Chỉ cần bạn giải một cách rõ ràng bài toán fuzzy trên matlab, mọi thành viên có kinh nghiệm của picvietnam đều có thể giúp bạn lập trình trên PIC một cách rất nhanh chóng.

              Đừng vội quan tâm tới vi điều khiển ở giai đoạn này, hãy quan tâm đến bài toán fuzzy một cách nghiêm túc.

              Chúc vui.
              Công ty TNHH Thương mại và Giao nhận R&P
              store.hn@rpc.vn - store.hcm@rpc.vn

              Học PIC như thế nào?

              Comment

              • falleaf
                PIC Bang chủ
                • May 2005
                • 2627

                #8
                Thực hành một bộ điều khiển fuzzy với PIC

                Hãy chuẩn bị những linh kiện sau để bắt đầu


                Part
                Description
                PIC18C452
                PIC18C452-JW
                7805
                7805 in TO-220 Package
                MAX232
                Maxim MAX232
                IRF510
                IRF510 N-Channel MOSFET in TO-220 Package
                OPB804
                OPB804 "Slotted Opto Isolator Switch" or equivalent modified as described in the text
                LED
                8x LED, Individual or use 10x LED "Bargraph" Display
                4 MHz
                4 MHz Ceramic Resonator with Internal Capacitors
                10K
                2x 10K, 1/4 Watt Resistors
                220
                220 Ohm, 1/4 Watt Resistor
                10K Pot
                10K Single Turn Potentiometer
                0.1 uF
                2x 0.1 uF, 16 Volt Tantalum Capacitors
                1.0 uF
                5x 1.0 uF, 16 Volt Tantalum Capacitors
                Miscellaneous
                Prototyping Card, Wiring, +12 Volt 500 mA Power Supply, 8x Screw Terminal
                Công ty TNHH Thương mại và Giao nhận R&P
                store.hn@rpc.vn - store.hcm@rpc.vn

                Học PIC như thế nào?

                Comment

                • falleaf
                  PIC Bang chủ
                  • May 2005
                  • 2627

                  #9
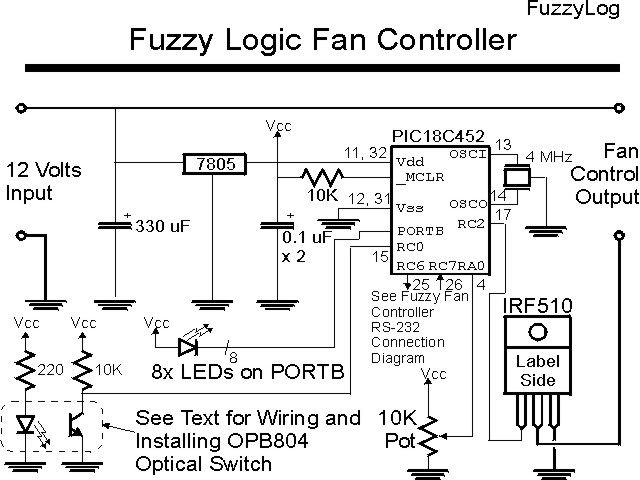
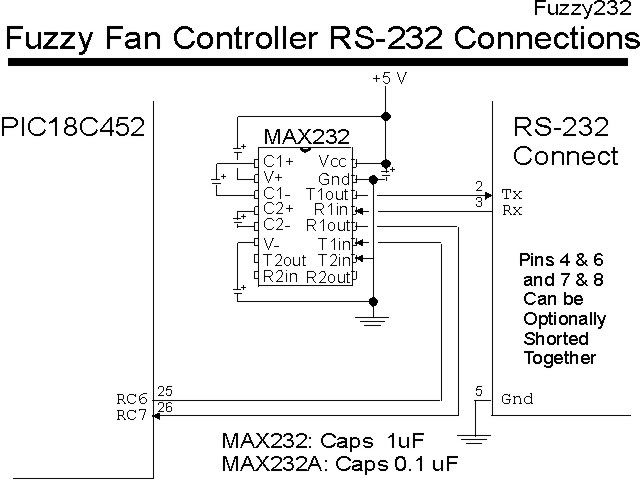
                  Sơ đồ nguyên lý


                  Công ty TNHH Thương mại và Giao nhận R&P
                  store.hn@rpc.vn - store.hcm@rpc.vn

                  Học PIC như thế nào?

                  Comment

                  • falleaf
                    PIC Bang chủ
                    • May 2005
                    • 2627

                    #10
                    Source code

                    Phần khai báo

                    Code:
                     title  "fuzzy2 - PIC18C452 Fuzzy Logic Fan Controller"
                    #define nDebug
                    ;
                    ;  This application uses the "fuzzyTECH" Heater/Motor control Interface
                    ;   to implement a Fuzzy Logic Fan Controller on the PIC18C452.  To simplify the
                    ;   software, the built in functions of the PICmicro to simplify the code development
                    ;   tasks.  This application runs in two modes, a basic POT Interface and a fuzzy logic
                    ;   control interface.  
                    ;
                    ;  The Difference between Fuzzy1 and Fuzzy2 is that Fuzzy2 Accepts Deltas to the PWM.
                    ;   This was done to see if the Oscillations can be eliminated.  
                    ;
                    ;  Hardware Notes:
                    ;  PIC18C452 running at 4 MHz with "_MCLR" pulled up
                    ;  Clock is running with the 4x PLL Enabled
                    ;  LED Displays:
                    #define Polling PORTB, 7
                    #define Sending PORTB, 6
                    #define Receive PORTB, 5
                    ;  RA2 - Pot Input Pin
                    #define PotIn   PORTA, 2
                    ;  RC2 - PWM Output Pin
                    #define PWMOut  PORTC, 2
                    ;
                    ;
                      LIST R=DEC, F=INHX32
                      INCLUDE "p18c452.inc"
                    
                    
                    ;  Register Usage
                     CBLOCK 0x000
                    TMR1Save:2						;  TMR1 Count Save Value
                    DDSave, DDOut:4						;  DecDisplay Variables
                    Dlay:3							;  Delay 1 Second
                    SetSpeed, DeltaSpeed, LEDTemp				;  Output Values
                    RXData:16						;  Want to Be able to Delete DPs
                    NewPWM, TempPWM						;  New PWM Value
                     ENDC
                    
                    ;  Macros
                    TXOut Macro			;  Transmit the Data in "w"
                     ifdef Debug
                      nop
                      nop
                     else
                      btfss   TXSTA, TRMT		;  Wait for the Previous Byte to be Sent
                       bra    $ - (2 * 1)
                     endif
                      movwf   TXREG			;  Output the Digit 
                      btg     Sending		;  Indicate Data Being Sent
                     endm
                    
                    
                     PAGE
                     __CONFIG _CONFIG0, _CP_OFF_0
                     __CONFIG _CONFIG1, _OSCS_OFF_1 & _HSPLL_OSC_1
                     __CONFIG _CONFIG2, _PWRT_ON_2 & _BOR_ON_2 & _BORV_42_2
                     __CONFIG _CONFIG3, _WDT_OFF_3 
                     __CONFIG _CONFIG5, _CCP2MX_OFF_5     
                     __CONFIG _CONFIG6, _STVR_OFF_6
                                                    ;  Note that the WatchDog Timer is OFF
                    
                    ;  Mainline of "Fuzzy1"
                      org     0			;  Reset Vector
                    
                     variable i = 0			;  Clear the Start of Memory
                     ifdef Delete
                     while (i < 0x0100)
                      nop
                    i = i + 1
                     endw
                     while (i < 0x0200)
                      nop
                    i = i + 1
                     endw
                     while (i < 0x0300)
                      nop
                    i = i + 1
                     endw
                     while (i < 0x0400)
                      nop
                    i = i + 1
                     endw
                     while (i < 0x0500)
                      nop
                    i = i + 1
                     endw
                     endif
                    
                      setf    PORTB
                      clrf    TRISB			;  Use PORTB for Output
                    
                      movlw   0x002			;  Set ADC to Fosc/8, ADFM "Left" Justified
                      movwf   ADCON1		;   AN2 is the ADC Select
                      movlw   0x051				
                      movwf   ADCON0
                    
                      movlw   200			;  Setup the 20 KHz PWM
                      movwf   PR2
                      movlw   0x004			;  On TMR2
                      movwf   T2CON
                    
                      movlw   100			;  Start with a 50% Duty Cycle
                      movwf   CCPR1L
                    
                      bcf     TRISC, 2
                    
                      movlw   0x00F			;  Enable PWM Mode
                      movwf   CCP1CON
                    
                      movlw   0x020			;  Enable the RS-232 Port
                      movwf   TXSTA
                      movlw   0x090
                      movwf   RCSTA
                    
                      movlw   25			;  Run the Data Output at 9600 bps
                      movwf   SPBRG			;   - Note this is 2400 bps Except for the 
                    
                      movlw   0x002			;  Setup TMR1
                      movwf   T1CON
                    Công ty TNHH Thương mại và Giao nhận R&P
                    store.hn@rpc.vn - store.hcm@rpc.vn

                    Học PIC như thế nào?

                    Comment

                    • falleaf
                      PIC Bang chủ
                      • May 2005
                      • 2627

                      #11
                      Source code (tiếp theo và hết)

                      Phần vòng lặp chính

                      Code:
                      Loop
                      
                       ifdef Debug
                        movlw   1
                       else
                        movlw   4			;  Wait a Quarter Second
                       endif
                        movwf   Dlay + 2
                      
                        clrf    TMR1H			;  Setup the Timer
                        clrf    TMR1L
                        bsf     T1CON, TMR1ON		;  Enable the Counter
                      
                      SecondLoopStart
                       ifdef Debug
                        movlw   1
                       else
                        movlw   HIGH (50000 + 255)	;  Inner Loop is 1/16 Second
                       endif
                        movwf   Dlay + 1
                       ifdef Debug
                        movlw   1
                       else
                        movlw   LOW (50000 + 255)
                       endif
                      SecondLoop
                        addlw   0x0FF
                        btfsc   STATUS, Z
                         decfsz Dlay + 1, f
                          bra   SecondLoop
                        decfsz  Dlay + 2, f
                         bra    SecondLoopStart
                      
                        bcf     T1CON, TMR1ON		;  Stop the Timer
                      
                        bsf     ADCON0, GO		;  Start the ADC Operation
                      
                        bsf     Polling		;  Not Polling Yet
                      
                        bcf     STATUS, C
                        rrcf    TMR1H, w		;  Read the Timer with the Range 0-800
                        movwf   TMR1Save + 1
                        rrcf    TMR1L, w
                        movwf   TMR1Save		;  In Range 0 to 400
                        bcf     STATUS, C
                        rrcf    TMR1Save + 1, f
                        rrcf    TMR1Save, f		;  In Range 0 to 200
                        bcf     STATUS, C		
                        rrcf    TMR1Save + 1, f
                        rrcf    TMR1Save, f		;  In Range 0 to 100
                      
                        movlw   100			;  Go to a Maximum of 100
                        subwf   TMR1Save, w
                        btfsc   STATUS, C
                         subwf  TMR1Save, f
                      
                        btfsc   ADCON0, GO		;  Wait for ADC to Complete
                         bra    $ - (2 * 1)
                      
                        movf    ADRESH, w		;  Get the MSB 8 Bits of the ADC Operation
                        mullw   100			;  Get the Fraction of 100
                        movf    PRODH, w
                        movwf   SetSpeed		;  Get the Set Speed to 100
                      
                        movf    TMR1Save, w		;  Get the "DeltaSpeed"
                        subwf   SetSpeed, w
                        movwf   DeltaSpeed
                      
                        btfsc   DeltaSpeed, 7		;  Output the Delta Speed on LEDs (RB0-RB4)
                         bra    LEDNegative
                        movlw   3			;  Is the Difference Between 0 and 2?  
                        subwf   DeltaSpeed, w
                        bc      LEDPosGreat
                        bcf     PORTB, 2		;  Yes, Nuts On
                        bra     RetryLoop
                      LEDPosGreat
                        movlw   6			;  Is the Difference Between 3 and 5
                        subwf   DeltaSpeed, w
                        bc      LEDPosOut
                        bcf     PORTB, 1		;  Yes, Slight Difference
                        bra     RetryLoop
                      LEDPosOut			;  Difference Greater than 5
                        bcf     PORTB, 0
                        bra     RetryLoop
                      LEDNegative			;  What is the Negative Value
                        movf    DeltaSpeed, w
                        sublw   0
                        movwf   LEDTemp
                        movlw   3			;  Between 0 and -2?
                        subwf   LEDTemp, w
                        bc      LEDNegGreat
                        bcf     PORTB, 2		;  Yes, Nuts On
                        bra     RetryLoop
                      LEDNegGreat
                        movlw   6			;  Difference Between -3 and -6?
                        subwf   LEDTemp, w
                        bc      LEDNegOut
                        bcf     PORTB, 3
                        bra     RetryLoop
                      LEDNegOut			;  Else, Out there
                        bcf     PORTB, 4
                      
                      RetryLoop			;  Keep Retrying Here
                      
                        clrf    FSR1H			;  Use FSR1 for the Received Data
                        movlw   LOW RXData
                        movwf   FSR1L
                      
                        movf    RCREG, w		;  Make Sure Receive is Clear
                        bcf     PIR1, RCIF		;  As well As Interrupt Requests
                      
                        movlw   0x01F			;  Turn Off Delta Speed LEDs
                        iorwf   PORTB, w
                      
                        movf    DeltaSpeed, w
                        movwf   DDSave		;  Send to the PC
                        call    DecDisplay		;  Send as a Decimal String
                      
                        movlw   0x01A			;  Output Ctrl-Z for End of the Record
                        call    CharDisplay
                        nop
                      
                      CharWaitLoop
                      
                       ifdef Debug			;  Wait for PC Reply
                        movlw   1
                       else
                        movlw   16			;  Wait a Full Second
                       endif
                        movwf   Dlay + 2
                      
                      ThirdLoopStart
                       ifdef Debug
                        movlw   1
                       else
                        movlw   HIGH (35714 + 255)	;  Inner Loop is 1/16 Second
                       endif
                        movwf   Dlay + 1
                       ifdef Debug
                        movlw   1
                       else
                        movlw   LOW (35714 + 255)
                       endif
                      ThirdLoop
                        btfsc   PIR1, RCIF		;  Has a Character Been Received?  
                         bra    GetChar
                        addlw   0x0FF
                        btfsc   STATUS, Z
                         decfsz Dlay + 1, f
                          bra   ThirdLoop
                        bcf     Polling		;  Turn on the "Polling" LED 
                        decfsz  Dlay + 2, f
                         bra    ThirdLoopStart
                      
                        bra     RetryLoop		;  Nothing Received, Try Sending Again
                      
                      GetChar				;  Get the Character and Compare to a Ctrl-Z
                      
                        movf    RCREG, w		;  Read Character and Reset the Interrupt Request Flag
                        bcf     PIR1, RCIF  
                        movwf   POSTINC1		;  Save the Character
                      
                        btg     Receive		;  Toggle the Receive LED
                      
                        xorlw   0x01A			;  End Character?  
                        bnz     CharWaitLoop		;  Yes, Have the New PWM Value
                      
                        bsf     Receive		;  Turn Off the LEDs
                        bsf     Polling
                        bsf     Sending
                      
                        clrf    NewPWM		;  Clear the New PWM Value
                      
                        movlw   RXData		;  Read the New PWM Value/Past +/-
                        movwf   FSR1L  
                      
                        movf    INDF1, w		;  Do we Have a Valid Decimal or +/-
                        xorlw   '+'			
                        bz      GetCharSkip		;  Yes, Skip Over
                        xorlw   '-' ^ '+'
                        bnz     GetCharLoop
                      GetCharSkip			;  Have a + or - Character
                        movf    POSTINC1, w		;  Increment FSR
                      
                      GetCharLoop			;  Loop Here Until \0 Char Encountered
                      
                        movf    NewPWM, w		;  Multiply the "NewPWM" Variable by 10 to be ready for the Next Value
                        mullw   10
                        movf    POSTINC1, w		;  Add the Next Variable to it
                        bz      HaveChar		;  At the End of the String
                        xorlw   "."			;  Have Decimal Point (with Everything to the Right)
                        bz      HaveChar
                        xorlw   "."
                        andlw   0x00F
                        addwf   PRODL, w
                        movwf   NewPWM
                        bra     GetCharLoop
                      
                      HaveChar			;  "NewPWM" has the New PWM Value
                      
                        movlw   '-'
                        xorwf   RXData, w		;  Is the First Character + or -?
                        bnz     MakePosPWM		;  Plus, Keep it the Way it is
                      
                      MakeNegPWM			;  Negative PWM, do the Subtraction
                      
                        movf    NewPWM, w		;  Negate the Value in NewPWM
                        subwf   CCPR1L, w
                        btfss   STATUS, C
                         movlw  0
                        movwf   CCPR1L		;  Update the PWM Value
                      
                        bra     Loop
                      
                      MakePosPWM			;  Add the Delta PWM to Get the New Value
                      
                        movf    NewPWM, w
                        addwf   CCPR1L, w
                        movwf   TempPWM
                        movlw   200			;  Go to a Maximum of 200
                        subwf   TempPWM, w
                        btfsc   STATUS, C
                         subwf  TempPWM, f
                      
                        movf    TempPWM, w		;  Get the New PWM Value
                        movwf   CCPR1L		
                        
                        bra     Loop			;  Finished with the Delta PWM Value, Loop Again
                      
                      
                      DecDisplay			;  Send the 8 Bit Value in "DDSave" as a Decimal Number
                      				;   Out Via RS-232
                        movlw   '0'			;  Set up the Data to Output
                        movwf   DDOut
                        movwf   DDOut + 1
                        movwf   DDOut + 2
                        movlw   '+'			;  Positive or Negative
                        movwf   DDOut + 3
                      
                        btfss   DDSave, 7		;  2's Complement Negative Number?
                         bra    DD_Hund		;  No, Calculate the Value
                      
                        movf    DDSave, w		;  Invert the Value to Convert
                        sublw   0
                        movwf   DDSave
                      
                        movlw   '-'
                        movwf   DDOut + 3
                      
                      DD_Hund				;  Find Out what each Digit Values are 
                        movlw   LOW 100
                        subwf   DDSave, w
                        bnc     DD_Ten		;  Can't Take Away any More Tens
                        movwf   DDSave
                        incf    DDOut + 2, f
                        bra     DD_Hund
                      
                      DD_Ten				;  Find Out what each Digit Values are 
                        movlw   10
                        subwf   DDSave, w
                        bnc     DD_One		;  Can't Take Away any More Ones
                        movwf   DDSave
                        incf    DDOut + 1, f
                        bra     DD_Ten
                      
                      DD_One				;  Find Out what each Digit Values are 
                        movlw   1
                        subwf   DDSave, w
                        bnc     DD_Display 		;  Display the Value
                        movwf   DDSave
                        incf    DDOut, f
                        bra     DD_One
                      
                      DD_Display
                      
                        clrf    FSR0H			;  Point to Data to Display
                        movlw   LOW DDOut + 3
                        movwf   FSR0L	
                      
                      DD_DNumber
                      
                        movf    POSTDEC0, w		;  Display the Digit
                       TXOut
                      
                        movlw   LOW (DDOut - 1)	;  Past the End?  
                        subwf   FSR0L, w
                        bnz     DD_DNumber		;  No, Loop Around Again
                      
                      DD_NUL				;  Output the NUL of the String
                        movlw   0x000
                       TXOut
                      
                        return
                      
                      
                      CharDisplay			;  Output the Character in "WREG"
                       TXOut
                      
                        return
                      
                      
                        end
                      Công ty TNHH Thương mại và Giao nhận R&P
                      store.hn@rpc.vn - store.hcm@rpc.vn

                      Học PIC như thế nào?

                      Comment

                      • bunyuki
                        Nhập môn đệ tử
                        • Jul 2006
                        • 8

                        #12
                        Cho em hỏi là bộ FuzzyTECH này có phiên bản fuzzyTECH MCU Pack for Embedded Control ko ạ, và nó có hỗ trợ dsPIC ko?
                        Em xin cảm ơn

                        Comment

                        • picvendor
                          Super Moderator
                          • Jun 2005
                          • 385

                          #13
                          Theo thông tin của fuzzyTech thì họ vẫn chưa hỗ trợ generate code cho dsPIC:


                          Tuy nhiên cái chính vẫn là tạo được code C, từ code C bạn có thể chỉnh các cài đặt để nó hoạt động với dsPIC. (tôi không làm việc với dsPIC nên không rõ cần thiết lập như thế nào)

                          Nhưng các bộ điều khiển fuzzy không cần đến mức độ tính toán mạnh như của dsPIC đâu, bạn chọn MCU là PIC16 chắc cũng đủ để làm fuzzy controller rồi.
                          Cách tìm link DOI để yêu cầu bài báo ở Sciencedirect: http://www.picvietnam.com/forum/show...&postcount=682
                          Cách tìm link DOI để yêu cầu bài báo ở IEEE: http://www.picvietnam.com/forum/show...&postcount=760
                          Cuộc thi thiết kế PIC (tạm ngưng): http://www.picvietnam.com/contest

                          Comment

                          • haiauxanh
                            Nhập môn đệ tử
                            • Feb 2009
                            • 1

                            #14
                            Bạn nào có hình ảnh của điều khiển Fuzzy controller thi gửi chô mình với. Mình muốn được hình dung rõ hơn về ứng dụng của điều khiển FZ trong thực tế.Cảm ơn nhieu......

                            Comment

                            • hgnamus
                              Nhập môn đệ tử
                              • Mar 2009
                              • 2

                              #15
                              có hướng dẫn sử dụng fuzzytech không vậy,làm ơn upload lên cho mình nha,mình cần gấp lắm,hoặc gời qua mail cũng được:
                              hgnam2005us@yahoo.com.vn

                              thank!!!

                              Comment

                              Working...